
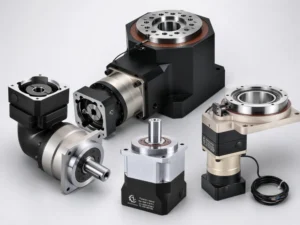
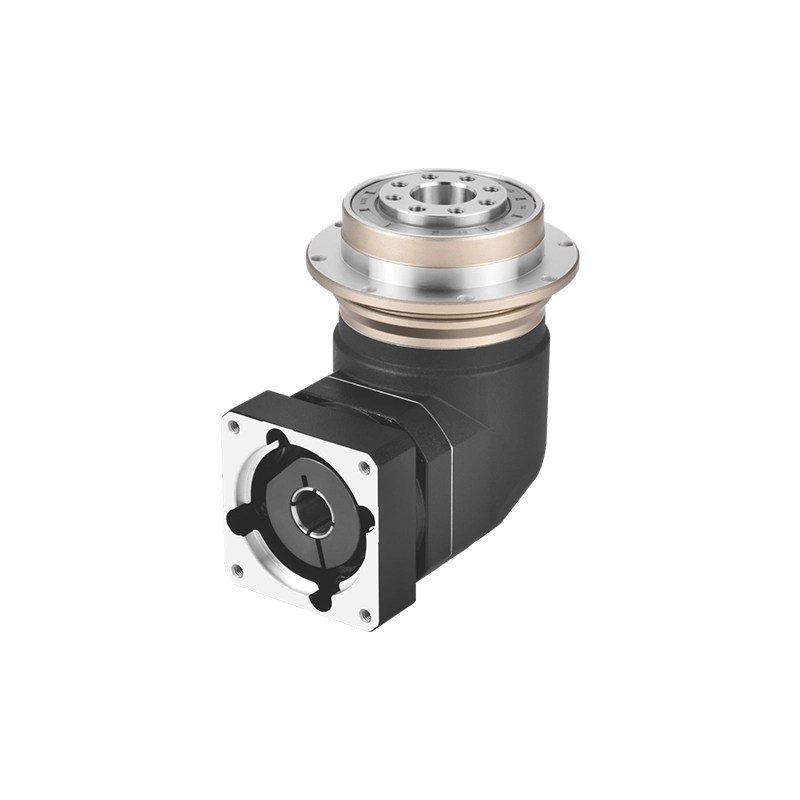
Choosing the right gearbox for stepper motor applications can substantially increase usable output torque, improve motion resolution and help the motor control higher-inertia loads. However, a planetary gearbox cannot be selected from the motor’s holding torque or NEMA frame size alone.
Many stepper systems operate in open-loop mode, although closed-loop stepper configurations are also available. In either case, reliable performance depends on matching the motor, gearbox and driven load around the real operating speed, acceleration cycle, backlash requirement and mechanical interface.
This guide explains how to select a stepper motor planetary gearbox for CNC equipment, indexing mechanisms, automated assembly systems, compact positioning modules and other industrial applications.
Why Use a Planetary Gearbox with a Stepper Motor?
Stepper motors are widely used where cost, straightforward control and repeatable incremental movement are important. Their main limitation is that available torque normally decreases as motor speed increases.
A correctly selected planetary gearbox for stepper motor use can address several practical motion-system requirements.
Higher Usable Output Torque
A planetary reducer multiplies the torque available at the output. Actual output torque is lower than the theoretical motor torque multiplied by the ratio because of gearbox efficiency, and it must remain within the reducer’s rated capacity.
The preliminary relationship is:
Estimated output torque = Motor torque at operating speed × Ratio × Gearbox efficiency
The important value is the motor torque available at the actual operating speed—not the static holding torque measured at zero speed.
Finer Output Resolution
A standard 1.8-degree stepper motor has 200 full steps per revolution. With a 5:1 reducer, the motor must turn five revolutions to produce one output revolution, creating 1,000 theoretical full-step positions at the output.
This improves theoretical motion resolution, but it does not automatically guarantee equivalent absolute positioning accuracy. Gearbox backlash, motor step-angle error, shaft deflection, load compliance and assembly tolerances still affect the final machine position.
Improved Control of High-Inertia Loads
A gearbox reduces the load inertia reflected to the motor by approximately the square of the reduction ratio. In a simplified model, a 3:1 ratio reduces reflected load inertia by approximately 9:1.
This can make acceleration easier to control and reduce the risk of stalling or losing steps. The final result still depends on the complete motion profile, motor torque-speed curve and mechanical load.
A More Useful Motor Operating Range
A stepper motor planetary gearbox allows the motor to operate at a higher speed while the machine receives lower output speed and higher torque. This can be useful when the required load speed and torque do not match the motor’s direct-drive operating range.
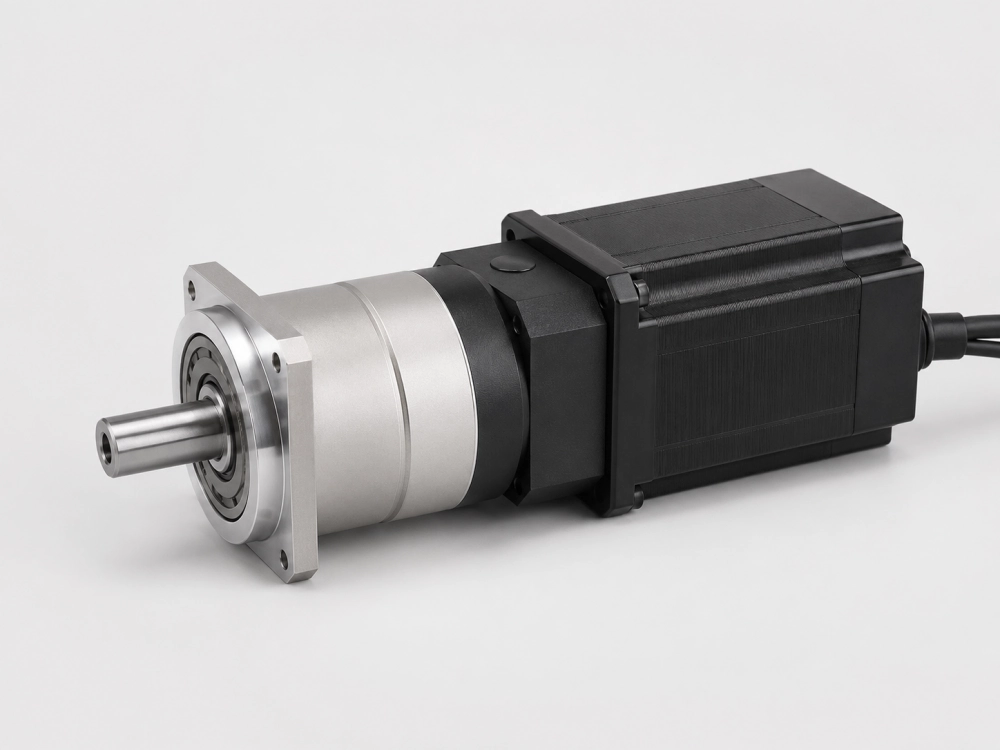
Understand NEMA Frame Compatibility
A NEMA planetary gearbox is commonly matched with a stepper motor identified by its NEMA frame size. The NEMA designation primarily describes the motor mounting-face dimensions. It does not define the motor’s torque, shaft length, electrical characteristics or complete operating performance.
Common stepper motor frames include:
- NEMA 17: approximately 42 mm mounting-face size, commonly used in compact mechanisms and light-duty automation
- NEMA 23: approximately 57 mm mounting-face size, widely used in CNC routers, positioning stages and packaging equipment
- NEMA 34: approximately 86 mm mounting-face size, used for heavier industrial axes and higher-load automation
- NEMA 42: approximately 110 mm mounting-face size, used in larger high-torque systems
These frame sizes are useful starting points, but two motors with the same NEMA designation can still have different shaft diameters, shaft lengths, pilot dimensions and mounting-hole details.
Confirm the Motor Interface Before Ordering
The input adapter and coupling must match the exact stepper motor—not only its NEMA number. A correct mechanical interface keeps the motor and reducer concentric and allows torque to pass through the coupling without slipping or creating excessive bearing load.
Before ordering a gearbox for stepper motor, provide:
- Motor manufacturer and complete model number
- NEMA frame size
- Motor flange dimensions
- Pilot diameter and pilot depth
- Mounting-hole size and spacing
- Motor shaft diameter
- Usable shaft length
- Keyway or flat dimensions, if present
The pilot locates the motor accurately relative to the gearbox input. Mounting bolts hold the assembly together, but they should not be relied on to correct an inaccurate pilot or coupling fit.
PlanetDrivePro supplies precision planetary reducers with configurable motor adapters. Compatibility must be confirmed from the actual motor drawing because available adapters and coupling dimensions vary by gearbox series and frame size.
Select the Ratio from Speed and Load Requirements
Gear ratio determines the relationship between motor speed and reducer output speed:
Output speed = Motor operating speed ÷ Gear ratio
If a stepper motor operates at 600 rpm and the machine requires 120 rpm, the preliminary ratio is:
600 ÷ 120 = 5:1
This calculation provides a starting point, but the final ratio must also satisfy:
- Required output torque
- Stepper torque available at the planned motor speed
- Required acceleration time
- Maximum permitted gearbox input speed
- Required output resolution
- Available standard gearbox ratios
Common planetary reducer ratios for stepper systems often include 3:1, 4:1, 5:1, 7:1 and 10:1. Higher multi-stage ratios may also be available, but a higher ratio is not automatically better.
An unnecessarily high ratio can reduce the maximum machine speed and require the motor to run faster than expected. The final ratio should come from the required speed and torque window rather than from torque multiplication alone.
Use the Stepper Motor Torque-Speed Curve
Holding torque is measured while the motor is energized but stationary. It is useful for comparing motors, but it does not represent the torque available at normal operating speed.
As step frequency increases, winding inductance and drive limitations reduce the current’s ability to reach its commanded value. Available torque can therefore fall sharply at higher motor speed.
When sizing a planetary gearbox for stepper motor applications, obtain the motor torque-speed curve for the intended:
- Driver voltage
- Phase current
- Wiring configuration
- Microstepping setting
- Acceleration profile
Use the torque available at the actual operating speed and retain a practical margin. Selecting from holding torque alone can create a system that appears strong on paper but stalls during acceleration.
Check Starting and Acceleration Torque
The reducer must withstand more than steady running torque. A positioning system may accelerate, stop and reverse many times per minute.
Separate the following load conditions:
- Continuous torque: torque required during steady movement
- Acceleration torque: torque required to increase load speed
- Deceleration torque: torque generated while slowing the load
- Reversing torque: alternating load during direction changes
- Emergency torque: short-duration torque caused by an abnormal stop or jam
A torque peak occurring every machine cycle is not a rare emergency event. It forms part of the normal duty profile and should be considered when selecting the reducer’s rated torque and expected service life.
Understand Resolution, Accuracy and Repeatability
Resolution, accuracy and repeatability describe different aspects of motion performance.
- Resolution is the smallest theoretical command increment.
- Accuracy is how closely the real output reaches the commanded position.
- Repeatability is how consistently the system returns to the same position.
A reducer increases theoretical output resolution because the motor turns through more steps for each output revolution. However, the complete positioning accuracy also depends on:
- Motor step-angle tolerance
- Gearbox backlash
- Gear transmission error
- Coupling stiffness
- Output shaft and bearing deflection
- Machine-frame rigidity
- Load vibration and external force
This distinction is important when selecting a NEMA planetary gearbox. A system can have very fine commanded resolution without achieving the same absolute mechanical accuracy.
Choose Backlash from the Machine Accuracy Budget
Backlash is the angular clearance observed at the output when the direction of rotation reverses. It is especially important in bidirectional positioning, contouring and indexing applications.
The following ranges can be used as preliminary reference points, but they are not universal acceptance limits:
- Approximately 8–10 arcmin: may suit general automation and unidirectional positioning where moderate clearance is acceptable
- Approximately 5 arcmin or lower: may suit more demanding indexing, dispensing and CNC-related mechanisms
- Approximately 3 arcmin or lower: may be considered for higher-precision reversing and coordinated-motion applications
The allowable gearbox backlash should be derived from the complete machine accuracy budget. Ballscrews, belts, couplings, bearings and structural deflection can contribute more positioning error than the gearbox itself.
Choosing the lowest available backlash grade may increase cost without improving real machine performance if other components remain flexible or inaccurate.
Check the Gearbox Input-Speed Limit
A stepper motor may briefly operate at a speed above its normal working range during rapid movement. Compare the motor’s highest programmed speed with both the nominal and maximum input-speed ratings of the gearbox.
Nominal input speed normally represents a sustainable condition. Maximum input speed may only be allowed for short periods.
High input speed increases losses in the gears, bearings, seals and lubricant. A gear reducer stepper assembly can therefore develop excess heat even when output torque appears moderate.
For machines with frequent high-speed moves, provide the complete motion cycle rather than only the maximum rpm.
Check Output Radial and Axial Loads
The reducer output bearing may need to support forces produced by a pulley, belt, sprocket, pinion, leadscrew or external mechanism.
A small pulley or highly tensioned belt can produce substantial radial load. Placing the load far from the gearbox output face increases the bending moment on the shaft.
Provide:
- Output connection type
- Pulley, sprocket or pinion diameter
- Distance from the output face to the load center
- Direction of the radial force
- Expected axial force
- Whether the driven shaft has an external support bearing
A gearbox can have sufficient torque capacity but insufficient bearing capacity for the connected load. Output torque and shaft-load limits must be checked separately.
Choose Inline or Right-Angle Mounting
Inline Planetary Gearbox
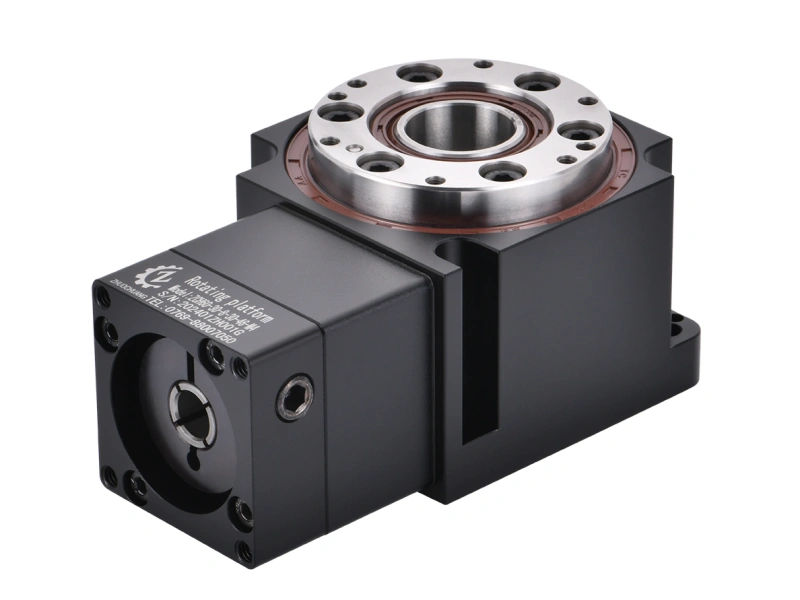
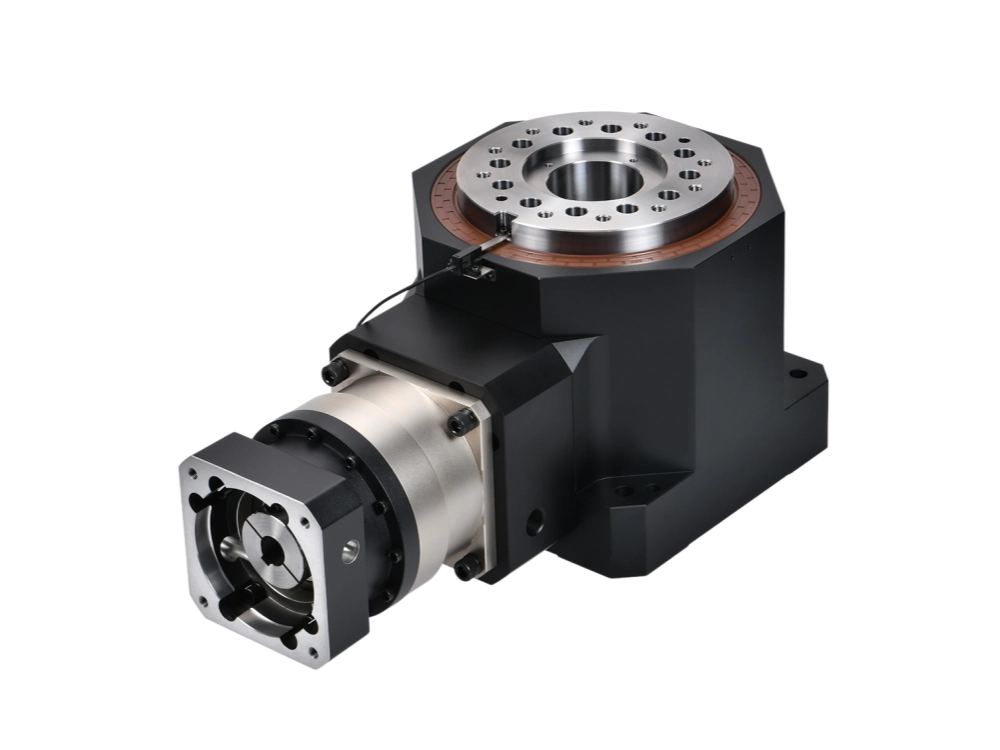
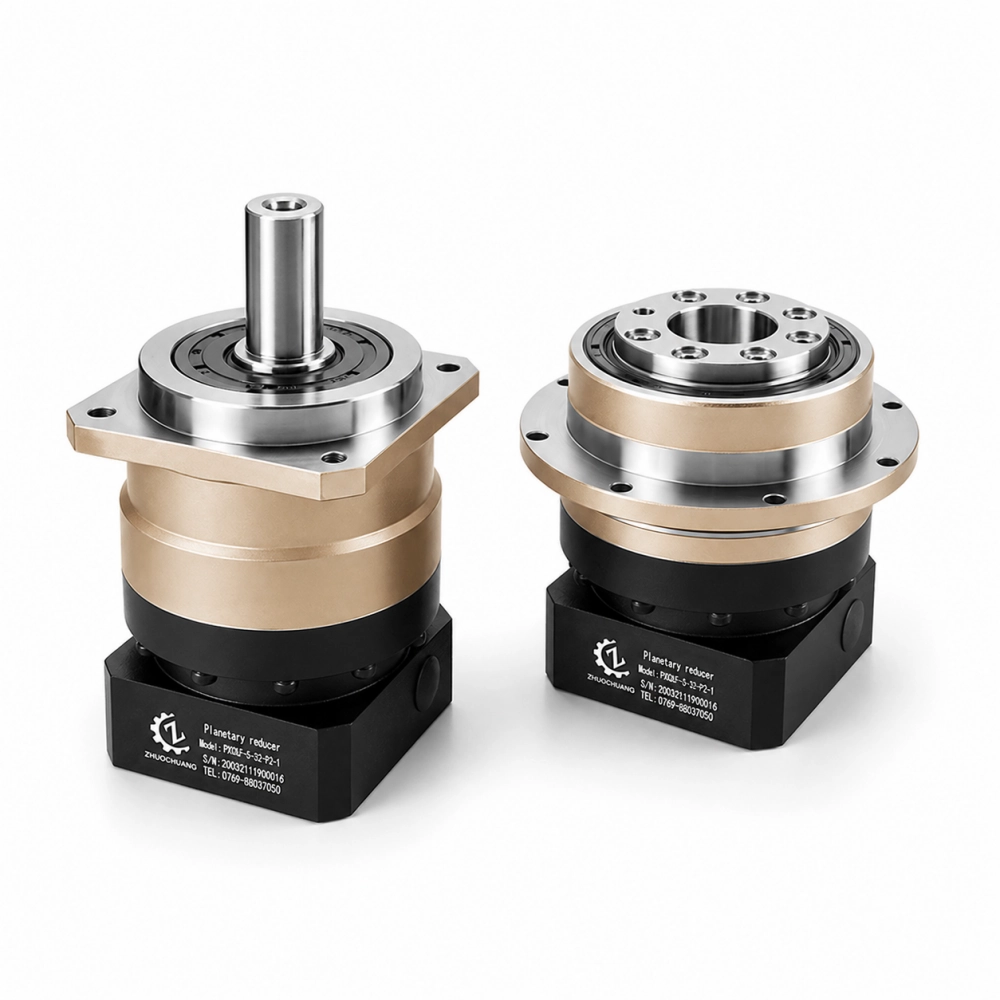
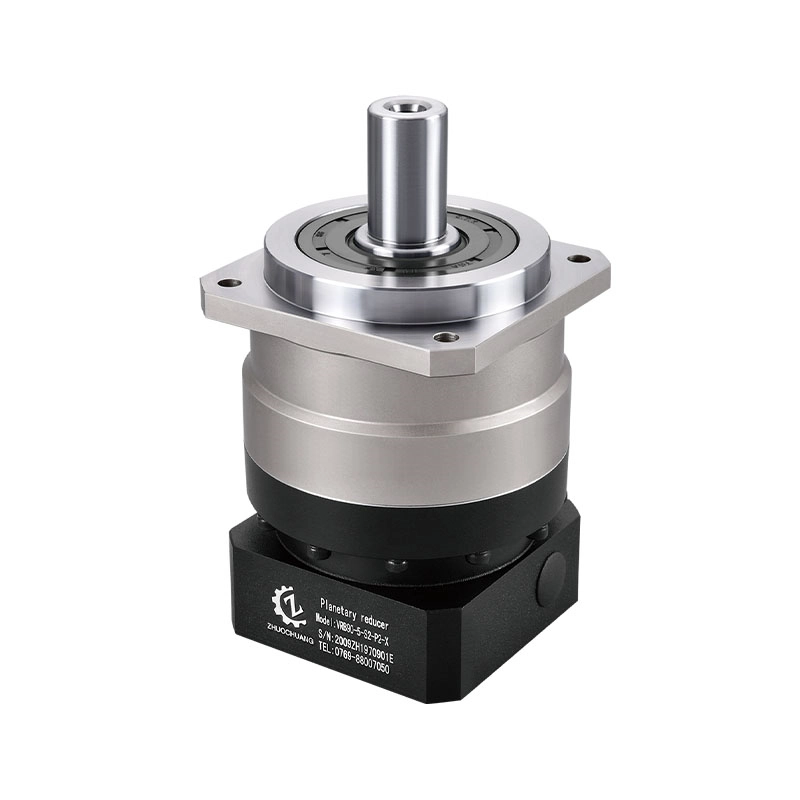
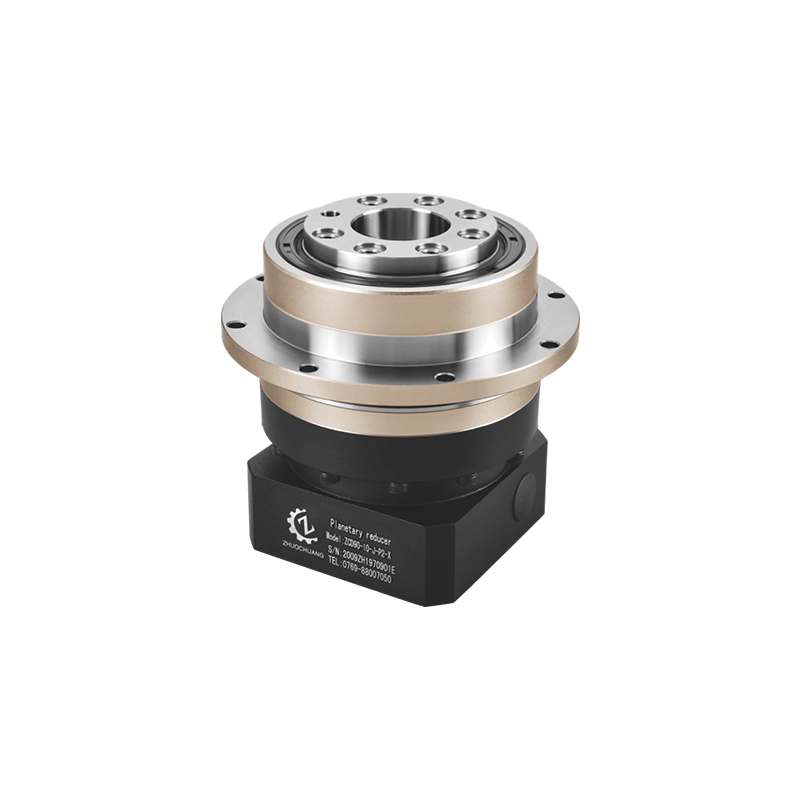
An inline planetary gearbox keeps the stepper motor and output shaft on the same axis. It provides a direct transmission path and is commonly used in CNC axes, positioning stages, indexing mechanisms and automated assembly modules.
PlanetDrivePro’s VRB Series and ZCD Series are available for compact inline automation layouts. Motor-interface compatibility should be confirmed using the exact motor drawing.
Right-Angle Planetary Gearbox
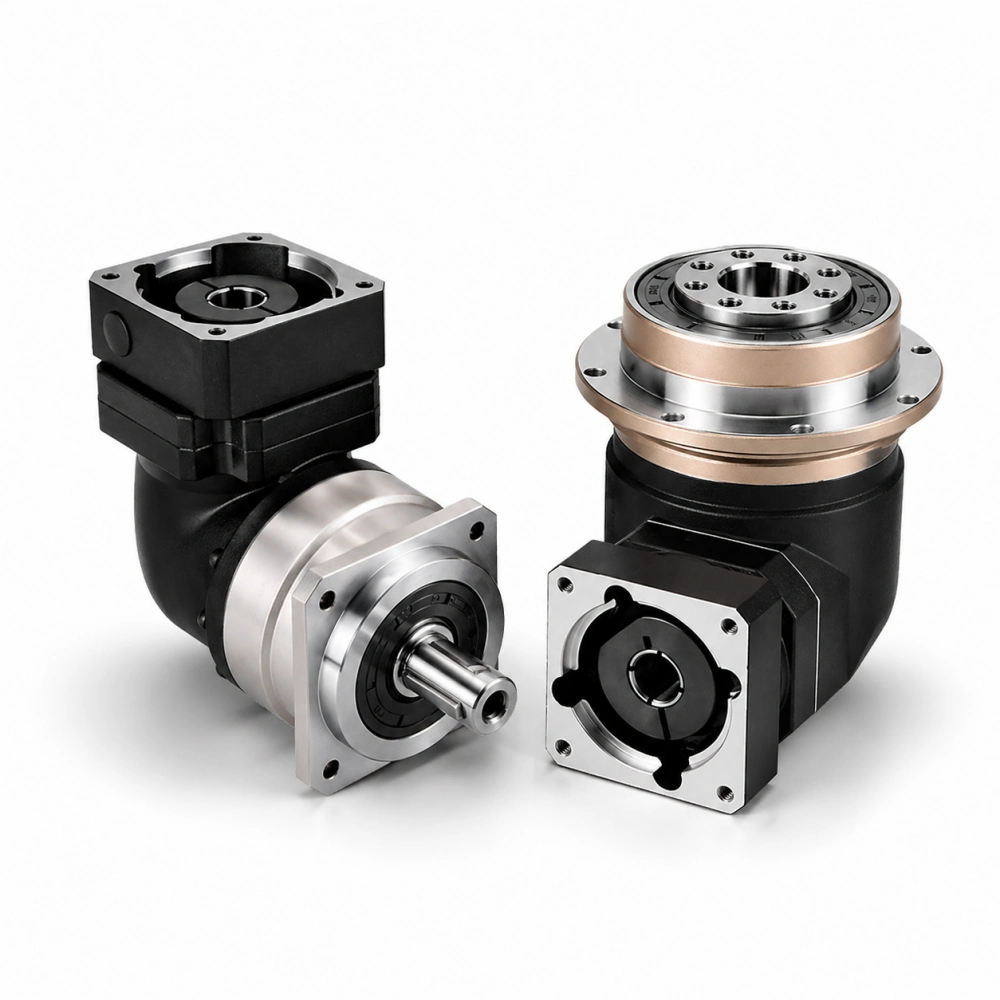
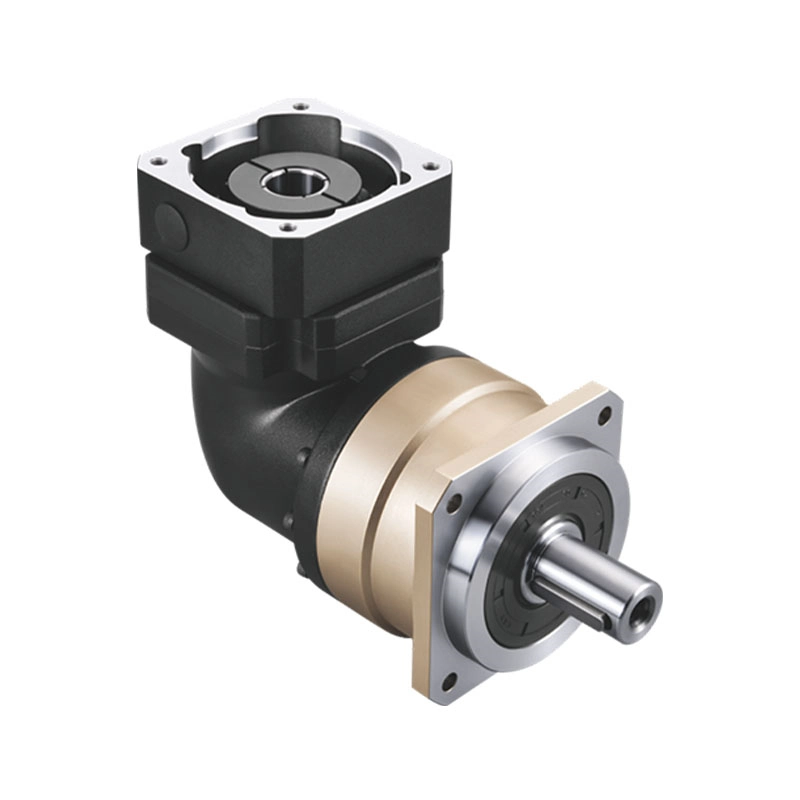
A right-angle reducer places the motor at 90 degrees to the output axis. It is useful when axial space is limited or when the motor must fit beside the driven mechanism.
The VRBR Series right-angle planetary gearbox provides a space-saving layout for compatible motor-driven equipment.
When comparing the two configurations, consider the complete installation envelope, cable direction, maintenance access and output load—not only the reducer dimensions.
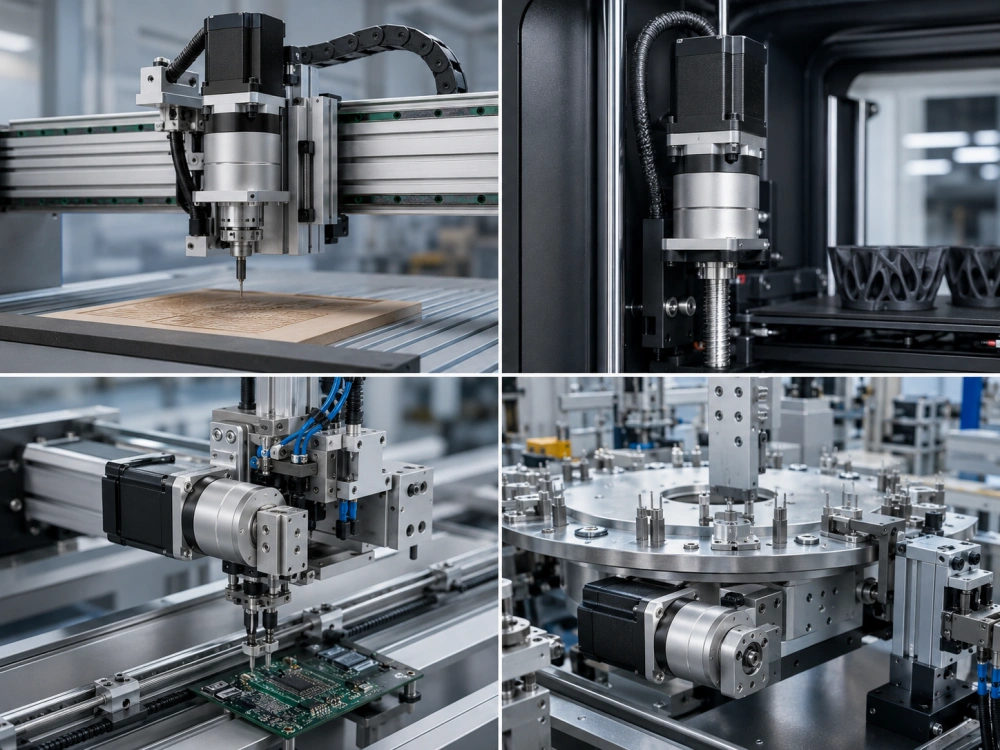
Common Stepper Motor Planetary Gearbox Applications
CNC Routers and Engraving Machines
A gearbox for stepper motor drive can increase available axis torque and help control higher-inertia mechanisms. The final ratio must be calculated from axis speed, cutting load, ballscrew or rack geometry and the motor torque-speed curve.
Automated Assembly Equipment
Indexing fixtures, screwdriving stations, dispensing systems and component-transfer mechanisms use geared stepper motors when repeatable incremental movement is needed without the cost of a full servo system.
Pick-and-Place Mechanisms
Planetary reducers can help a stepper motor control the acceleration of a moving arm or slide. High cycle rates require careful checking of motor torque at speed, repeated acceleration torque and gearbox thermal capacity.
Rotary Fixtures and Indexing Devices
A geared stepper motor can provide lower output speed and higher torque for rotary positioning. Backlash becomes important when the fixture approaches positions from both directions.
Compact Automation Modules
Small material-feeding, inspection and laboratory mechanisms may use NEMA 17 or NEMA 23 motors with compact planetary reducers. The motor frame alone does not determine the correct gearbox; the real load and cycle must still be evaluated.
Planetary Gearbox vs Other Stepper Reduction Methods
| Reduction method | Main advantage | Main limitation | Typical fit |
|---|---|---|---|
| Planetary gearbox | Compact size, high torque density and relatively low backlash | Higher cost than basic reduction methods | Compact positioning and industrial automation |
| Spur gearbox | Simple construction and lower cost | Generally higher backlash and lower torque density | Basic low-cost mechanisms |
| Worm gearbox | High ratio and right-angle arrangement | Lower efficiency and generally greater backlash | Slow, simple motion where precision is limited |
| Timing-belt reduction | Flexible center distance and low moving mass | Belt elasticity, tensioning and larger installation space | Separated shafts and lightweight axes |
A planetary design is especially useful when the machine requires a compact coaxial arrangement, higher torque density, controlled backlash and a rigid motor-to-load connection. It is not automatically the best option for every mechanism.
Common Selection Mistakes
Selecting from Holding Torque
Holding torque is measured at zero speed. Use the motor torque-speed curve to find the torque available during actual movement.
Choosing the Ratio Only to Increase Torque
A higher ratio also reduces output speed and increases the motor speed needed to reach the machine target. Speed, torque and resolution must be evaluated together.
Assuming the NEMA Frame Guarantees Fit
The NEMA frame identifies important mounting dimensions but does not guarantee that the shaft, pilot and coupling dimensions match the reducer.
Ignoring Backlash in Reversing Motion
Fine theoretical step resolution cannot remove gearbox clearance when the axis reverses direction.
Ignoring Repeated Acceleration
A torque peak that occurs every cycle belongs to normal operation and should not be treated as an occasional emergency event.
Overlooking the Output Bearing Load
Pulleys, belts and sprockets can overload the output bearing even when transmitted torque remains within the rated range.
Using Unverified Product Specifications
Ratio, backlash, efficiency, input speed and torque limits vary by gearbox series and size. Confirm the data for the exact model rather than applying one specification to an entire product category.
Stepper Motor Gearbox RFQ Checklist
| Selection item | Information to provide |
|---|---|
| Motor identification | Manufacturer, complete model and NEMA frame |
| Motor performance | Holding torque and torque-speed curve under the intended driver settings |
| Motor speed | Normal and maximum programmed rpm |
| Required output | Output speed, continuous torque and acceleration torque |
| Motion cycle | Acceleration time, running time, dwell time and cycles per minute |
| Positioning requirement | Required resolution, repeatability and allowable backlash |
| Motor interface | Flange, pilot, bolt-hole, shaft and keyway dimensions |
| Output connection | Coupling, pulley, sprocket, pinion, leadscrew or flange |
| External load | Radial load, axial load and distance from the output face |
| Installation | Inline or right-angle arrangement and available space |
| Supporting information | Motor drawing, machine layout, load data and photographs |
Frequently Asked Questions
Can Any Planetary Gearbox Be Used with a Stepper Motor?
Not automatically. The gearbox must match the motor’s operating speed, usable torque, shaft dimensions, flange pattern and application load. Its backlash, input-speed limit and output bearing capacity must also suit the machine.
What Gear Ratio Is Best for a Stepper Motor?
There is no universal best ratio. Calculate the preliminary ratio from motor operating speed and required output speed, then confirm torque at speed, acceleration, available standard ratios and maximum gearbox input speed.
Does a Gearbox Improve Stepper Motor Accuracy?
A gearbox improves theoretical output resolution, but it does not automatically improve absolute accuracy. Backlash, motor step-angle error, transmission error, shaft deflection and machine rigidity still affect the real output position.
Can a Planetary Gearbox Prevent Missed Steps?
A suitable ratio can reduce reflected load inertia and increase available output torque, which may reduce the risk of missed steps. It cannot compensate for an undersized motor, excessive acceleration, poor driver settings or a mechanical jam.
How Do I Mount a Stepper Motor to a Planetary Gearbox?
First verify the motor flange, pilot, bolt-hole pattern, shaft diameter and shaft length. Use the correct adapter and coupling, insert the motor shaft according to the manufacturer’s instructions and tighten the coupling in the specified sequence and torque.
Can the Same NEMA Planetary Gearbox Fit Different Motors?
The main gearbox may support different motors through suitable input adapters and coupling bores. Compatibility must still be confirmed from the exact motor model and drawing.
Is a Clamping Hub Better Than a Keyed Connection?
A clamping hub provides a rigid and concentric connection when correctly sized and tightened. Keyed connections can also be reliable. The appropriate design depends on the motor shaft, transmitted torque, speed and reversing cycle.
Should I Buy an Integrated Geared Stepper Motor or Separate Components?
An integrated unit simplifies ordering and installation. Separate components provide more flexibility for changing the ratio, motor or gearbox during development and future maintenance.
Choosing a Stepper Motor Gearbox Supplier
A capable supplier should do more than confirm the motor’s NEMA number. When sourcing a stepper motor planetary gearbox, evaluate:
- Published torque, speed, backlash and bearing-load data
- Ability to review the motor torque-speed curve and motion cycle
- Motor-adapter and input-coupling capability
- Dimensional drawings and 3D model availability
- Quality-control and backlash-testing procedures
- Support for prototypes and OEM production
- Ability to configure inline and right-angle layouts
PlanetDrivePro is the international website of Dongguan Zhuochuang Precision Machinery Co., Ltd. We manufacture precision inline and right-angle planetary gearboxes for stepper and servo motor applications.
Available ratios, backlash grades and motor adapters vary by series and gearbox size. Send us the exact motor model and application data so that our team can confirm a compatible configuration.
Conclusion
Selecting a reliable gearbox for stepper motor applications requires more than matching a NEMA frame and nominal ratio. Use the motor’s real torque-speed curve, confirm the acceleration cycle and distinguish theoretical resolution from actual positioning accuracy.
The selected NEMA planetary gearbox must also match the motor shaft and flange, remain within its input-speed and torque limits, support the external output load and provide an appropriate backlash grade for the machine.
Supplying the complete motor drawing, load data and motion profile helps prevent missed steps, incorrect output speed, coupling problems, excessive backlash and premature gearbox wear.
Ready to Specify Your Stepper Motor Gearbox?
Send us your motor model, torque-speed curve, required output speed, load data and mounting drawing. Our engineering team will help you identify a suitable Zhuochuang planetary gearbox, ratio and motor adapter.
Get a quote within 24 hours with technical support from our gearbox specialists.
Request a Quote View Planetary GearboxesRelated Gearbox Guides
- Gearbox for Servo Motor: Choose the Right Reducer – Learn how servo dynamics, inertia and precision requirements affect gearbox selection.
- Planetary Gearbox Types: Inline and Right-Angle – Compare common planetary reducer configurations and machine layouts.
- Gear Reducer Basics: Types, Ratios and Selection – Review the terminology and selection factors used across industrial reducers.